网页
综合
更新时间 2026-11-17 09:57:03
Reachy 2: open-source humanoid robot for embodied AI
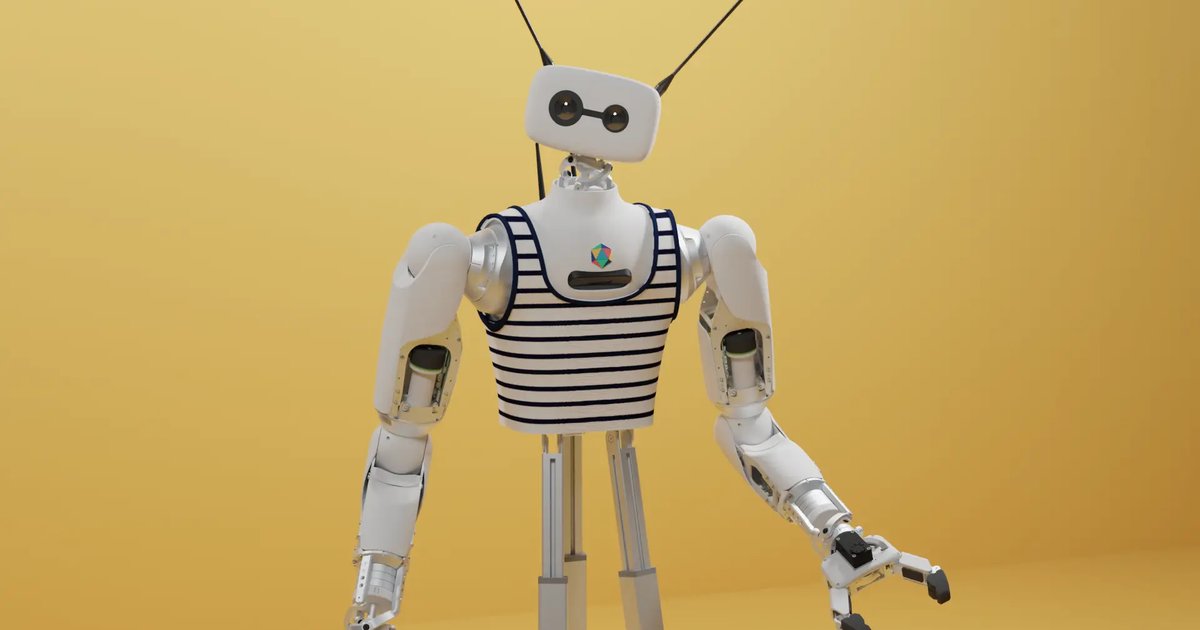
Open-source humanoid
The first open-source humanoid robot designed for embodied AI and real-world applications.
The ideal bimanual mobile manipulator for AI & robotics labs.
Fully open source. Teleoperated or controlled with Python. Runs on ROS 2 Humble.
Jump straight into our Python SDK or VR teleoperation app and start prototyping.
Truly useful robots need to learn how to grasp and use objects from our everyday environments - the office, our homes, a hospital, a shop.
Take control of Reachy 2 remotely using VR and our teleoperation application. Move its arms, hands and head, and see through Reachy's cameras to interact with the environment around the robot.
With 7 degrees of freedom, Reachy 2's arms mirror the dimensions, proportions and movements of an adult human arm. One arm can lift objects up to 3 kg and manipulate them with real dexterity.
Reachy 2 is available on an omnidirectional mobile base for a wider working space. Three omniwheels, a cylinder-like structure, a suite of sensors and a LiDAR make navigation effortless.
A machine that learns
Reachy 2's CPU-powered system delivers strong performance and seamless compatibility with modern AI frameworks - everything you need to explore and implement new learning models.
Omnidirectional base
Open hardware, open software, and a growing community. Start building embodied AI on a robot you can fully own and extend.
Expressive, open-source robots for AI builders and makers.
© 2026 Pollen Robotics · Open source under Apache 2.0
The first open-source humanoid robot designed for embodied AI and real-world applications.
The ideal bimanual mobile manipulator for AI & robotics labs.
Fully open source. Teleoperated or controlled with Python. Runs on ROS 2 Humble.
Jump straight into our Python SDK or VR teleoperation app and start prototyping.
Truly useful robots need to learn how to grasp and use objects from our everyday environments - the office, our homes, a hospital, a shop.
Take control of Reachy 2 remotely using VR and our teleoperation application. Move its arms, hands and head, and see through Reachy's cameras to interact with the environment around the robot.
With 7 degrees of freedom, Reachy 2's arms mirror the dimensions, proportions and movements of an adult human arm. One arm can lift objects up to 3 kg and manipulate them with real dexterity.
Reachy 2 is available on an omnidirectional mobile base for a wider working space. Three omniwheels, a cylinder-like structure, a suite of sensors and a LiDAR make navigation effortless.
A machine that learns
Reachy 2's CPU-powered system delivers strong performance and seamless compatibility with modern AI frameworks - everything you need to explore and implement new learning models.
Omnidirectional base
Open hardware, open software, and a growing community. Start building embodied AI on a robot you can fully own and extend.
Expressive, open-source robots for AI builders and makers.
© 2026 Pollen Robotics · Open source under Apache 2.0
本页为82搜索生成的网页快照,内容来自站内索引;演示数据的原文链接仅作示例。