网页
综合
更新时间 2026-11-15 00:02:44
Haimin Hu – I develop trustworthy robots that learn and teach.
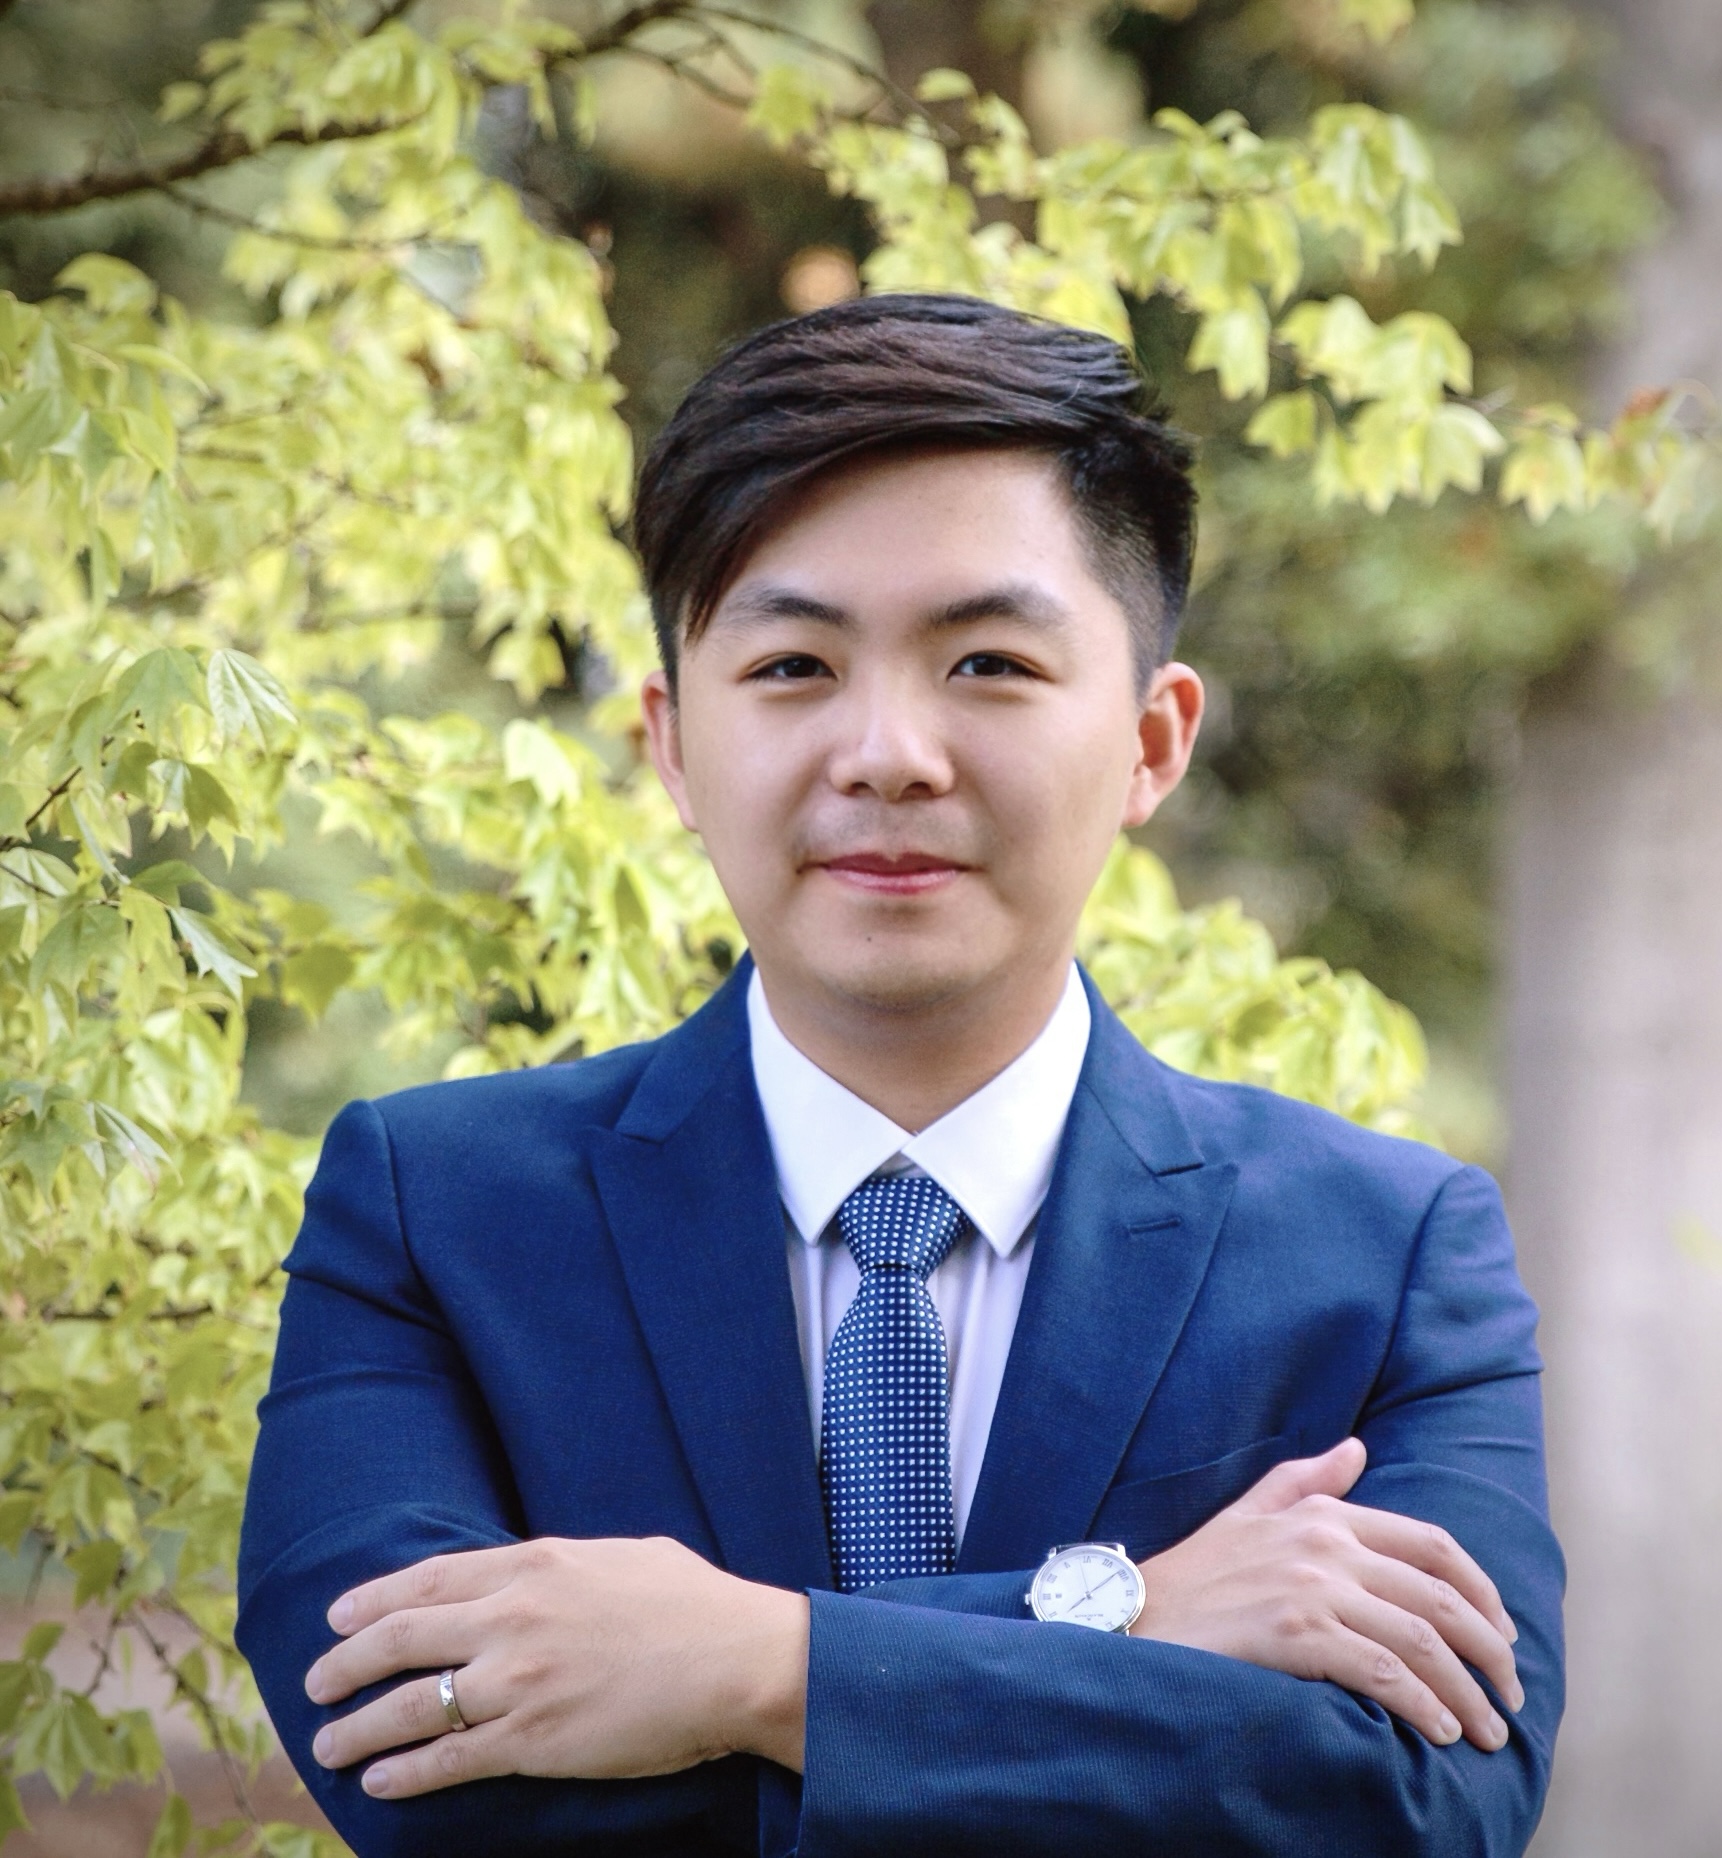
I develop trustworthy robots that learn and teach.
Contact: haimin@cs.jhu.edu
Hello and welcome! I am an Assistant Professor at JHU CS, where I direct the Alliance AI Lab. My research aims at enabling safe human-centered robotic systems that can be verified, deployed, and trusted. Towards this goal I work on new algorithms and theorems centered around dynamic game theory, integrating insights from machine learning and safety-critical control. I ground my work in real-world robotic and cyber-physical systems such as miniature autonomous vehicles, quadrupedal robots, AI-assisted race cars, and quadrotors. I am a 2026 Penn AI Fellow, 2025 RSS Pioneer, 2025 NSF CPS Rising Star, and 2024 HRI Pioneer.
Watch the JHU Alliance AI Lab Trailer:
Please see my updated research statement here: https://alliance-ai.cs.jhu.edu/research/
In case you are interested, below is my research statement in 2024.
Autonomous robots are becoming more versatile and widespread in our daily lives. From autonomous vehicles to companion robots for senior care, these human-centric systems must demonstrate a high degree of reliability in order to build trust and, ultimately, deliver social value. How safe is safe enough for robots to be wholeheartedly trusted by society? Is it sufficient if an autonomous vehicle can avoid hitting a fallen cyclist 99.9% of the time? What if this rate can only be achieved by the vehicle always stopping and waiting for the human to move out of the way?
My vision is to enable human-centered robotic systems that can be built, deployed, and verified with safety assurances under minimal performance loss. Towards this goal, my research focuses on interactive motion planning in the joint space of physical and information states (e.g., beliefs), actively ensuring safety and improving efficiency as robots autonomously navigate uncertain environments and interact with people. The key thrusts of my research include:
Planning while accounting for strategic interactions among many agents is hard, especially with uncertainties induced by learning components and indecisions! My solver draws insights from mixed-integer optimization, machine learning, and bifurcation theory, and runs in real-time for teamed robots on the ground and in the air.
Robots will be everywhere. How can we trust them to be safe and performant around people? My work showed that by planning and safeguarding in the joint space of physical and information states (generally, we call them doxo-physical states), we can ensure safety and maintain efficiency for human-robot interaction.
Computing a safety-assured controller is a fundamental open problem for robots with high-dimensional, nonlinear dynamics. I pioneered algorithms that learn robust neural controllers with theoretical guarantees on their training-time convergence and deployment-time safety.
Please explore my complete list of publications here. Here is my research statement:
Aug. 2020 – Aug. 2025, Electrical and Computer Engineering, Princeton University
Master of Arts, Doctor of Philosophy.
Aug. 2018 – May 2020, Electrical Engineering, University of Pennsylvania
Master of Science in Engineering.
Sep. 2014 – July 2018, Electronic and Information Engineering, ShanghaiTech University
Bachelor of Engineering (with high honors).
Aug. 2017 – June 2018, Electrical Engineering and Computer Sciences, University of California, Berkeley
I regularly publish in the following peer-reviewed journals and conference proceedings:
Please visit here for my publications. Here is my Google Scholar.
Contact: haimin@cs.jhu.edu
Hello and welcome! I am an Assistant Professor at JHU CS, where I direct the Alliance AI Lab. My research aims at enabling safe human-centered robotic systems that can be verified, deployed, and trusted. Towards this goal I work on new algorithms and theorems centered around dynamic game theory, integrating insights from machine learning and safety-critical control. I ground my work in real-world robotic and cyber-physical systems such as miniature autonomous vehicles, quadrupedal robots, AI-assisted race cars, and quadrotors. I am a 2026 Penn AI Fellow, 2025 RSS Pioneer, 2025 NSF CPS Rising Star, and 2024 HRI Pioneer.
Watch the JHU Alliance AI Lab Trailer:
Please see my updated research statement here: https://alliance-ai.cs.jhu.edu/research/
In case you are interested, below is my research statement in 2024.
Autonomous robots are becoming more versatile and widespread in our daily lives. From autonomous vehicles to companion robots for senior care, these human-centric systems must demonstrate a high degree of reliability in order to build trust and, ultimately, deliver social value. How safe is safe enough for robots to be wholeheartedly trusted by society? Is it sufficient if an autonomous vehicle can avoid hitting a fallen cyclist 99.9% of the time? What if this rate can only be achieved by the vehicle always stopping and waiting for the human to move out of the way?
My vision is to enable human-centered robotic systems that can be built, deployed, and verified with safety assurances under minimal performance loss. Towards this goal, my research focuses on interactive motion planning in the joint space of physical and information states (e.g., beliefs), actively ensuring safety and improving efficiency as robots autonomously navigate uncertain environments and interact with people. The key thrusts of my research include:
Planning while accounting for strategic interactions among many agents is hard, especially with uncertainties induced by learning components and indecisions! My solver draws insights from mixed-integer optimization, machine learning, and bifurcation theory, and runs in real-time for teamed robots on the ground and in the air.
Robots will be everywhere. How can we trust them to be safe and performant around people? My work showed that by planning and safeguarding in the joint space of physical and information states (generally, we call them doxo-physical states), we can ensure safety and maintain efficiency for human-robot interaction.
Computing a safety-assured controller is a fundamental open problem for robots with high-dimensional, nonlinear dynamics. I pioneered algorithms that learn robust neural controllers with theoretical guarantees on their training-time convergence and deployment-time safety.
Please explore my complete list of publications here. Here is my research statement:
Aug. 2020 – Aug. 2025, Electrical and Computer Engineering, Princeton University
Master of Arts, Doctor of Philosophy.
Aug. 2018 – May 2020, Electrical Engineering, University of Pennsylvania
Master of Science in Engineering.
Sep. 2014 – July 2018, Electronic and Information Engineering, ShanghaiTech University
Bachelor of Engineering (with high honors).
Aug. 2017 – June 2018, Electrical Engineering and Computer Sciences, University of California, Berkeley
I regularly publish in the following peer-reviewed journals and conference proceedings:
Please visit here for my publications. Here is my Google Scholar.
本页为82搜索生成的网页快照,内容来自站内索引;演示数据的原文链接仅作示例。